
@InProceedings{Dauner2026ARXIV,
	author = {Daniel Dauner and Valentin Charraut and Bastian Berle and Tianyu Li and Long Nguyen and Jiabao Wang and Changhui Jing and Maximilian Igl and Holger Caesar and Boris Ivanovic and Yiyi Liao and Andreas Geiger and Kashyap Chitta},
	title = {123D: Unifying Multi-Modal Autonomous Driving Data at Scale},
	booktitle = {arXiv.org},
	year = {2026},
}Long Nguyen
PhD Candidate · University of Tübingen · KE:SAI · ELLIS Institute Tübingen
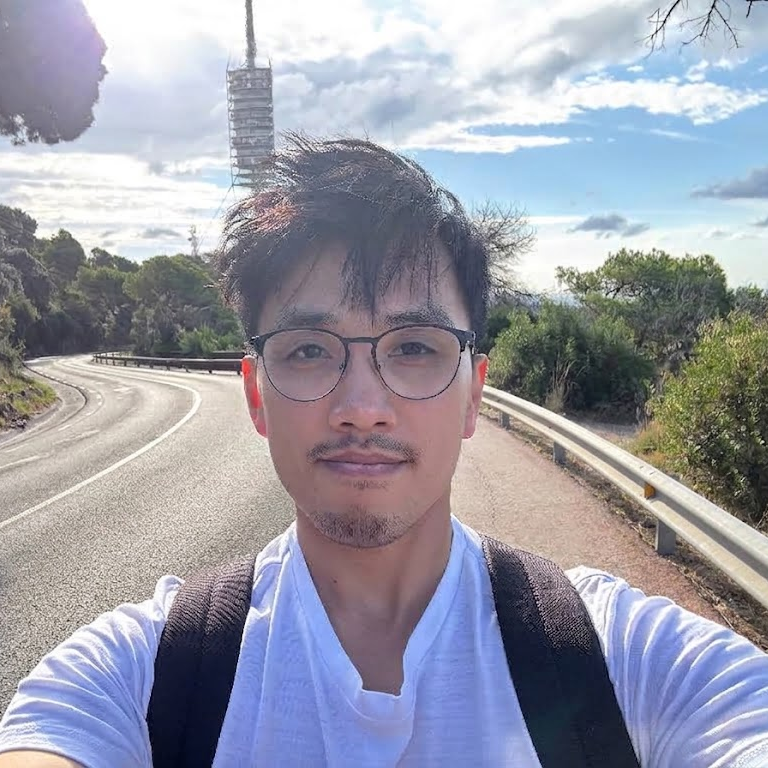
I am a researcher at KE:SAI, advised by Prof. Dr. Andreas Geiger in the Autonomous Vision Group at the University of Tübingen and Dr. Kashyap Chitta in the Physical AI Lab at the ELLIS Institute Tübingen.
My research focuses on end-to-end driving policies, which learn perception and planning jointly from raw sensor data. Two simple questions guide my work:
- What do imitation-learned policies really need to excel in closed loop?
- What makes a driving benchmark predictive of real-world performance?
I believe progress is best measured in closed loop, which makes simulation essential. I also believe in open research: sharing code, data, and models lets us build on each other's work.
I am always open to collaborations on policy learning, closed-loop benchmarking, and driving simulation. The best way to reach me is by email or LinkedIn.
Research interests Policy learning · Closed-loop benchmarking · Representation learning
News
- Oct 2026py123d_garage v0.2 released. Blog post Learning to Drive in a Day: An Open Recipe for End-to-End Driving Policies that Generalize across Benchmarks.
- Aug 2026DriveIRT released together with the NavHard-IRT leaderboard.
- Jun 2026LEAD presented at CVPR 2026. Blog post No More Shortcuts: Closed-Loop Driving Without Target Point Bias.
- May 2026Started my PhD journey, advised by Andreas Geiger and Kashyap Chitta.
- May 2026123D preprint released together with the py123d library.
- Dec 2025LEAD preprint on arXiv.
- Jun 20252nd place in the Waymo Open Dataset Vision-based End-to-End Driving Challenge.
Publications

Conference on Computer Vision and Pattern Recognition (CVPR), 2026
@InProceedings{Nguyen2026CVPR,
	author = {Long Nguyen and Micha Fauth and Bernhard Jaeger and Daniel Dauner and Maximilian Igl and Andreas Geiger and Kashyap Chitta},
	title = {LEAD: Minimizing Learner Expert Asymmetry in End-to-End Driving},
	booktitle = {Conference on Computer Vision and Pattern Recognition (CVPR)},
	year = {2026},
}
Open-Source Software
Open recipe for training and evaluating end-to-end driving policies on public data and benchmarks.
Open-source framework and model release, KE:SAI, 2026
Introducing Item Response Theory for driving benchmarks, enabling policy rankings by ability with uncertainty estimates.
Open-source Python library, KE:SAI, 2026
Awards and Service
Organizer, AlpaSim End-to-End Closed-Loop Driving Challenge
@misc{alpasim_challenge_2026,
  author       = {
    Watson, Michael and
    Chitta, Kashyap and
    Nguyen, Long and
    Wang, Caojun and
    Igl, Maximilian and
    Bursuc, Andrei and
    Rong, Frieda and
    Karkus, Peter and
    Da Col, Damiano and
    Tian, Haochen and
    Qiu, Yihang and
    Lew, William and
    Liao, Yiyi and
    Li, Hongyang and
    Ivanovic, Boris and
    Pavone, Marco
  },
  title        = {2026 {AlpaSim} End to End Driving Challenge},
  year         = {2026},
  url          = {https://huggingface.co/spaces/nvidia/AlpasimE2EClosedLoopChallenge2026},
}
Participant, Vision-based End-to-End Driving Challenge, 2nd Place
Education

Ph.D., Computer Science
M.Sc., Machine Learning

B.Sc., Medical Informatics
Grades follow the German scale, on which 1.0 is the best possible grade.